
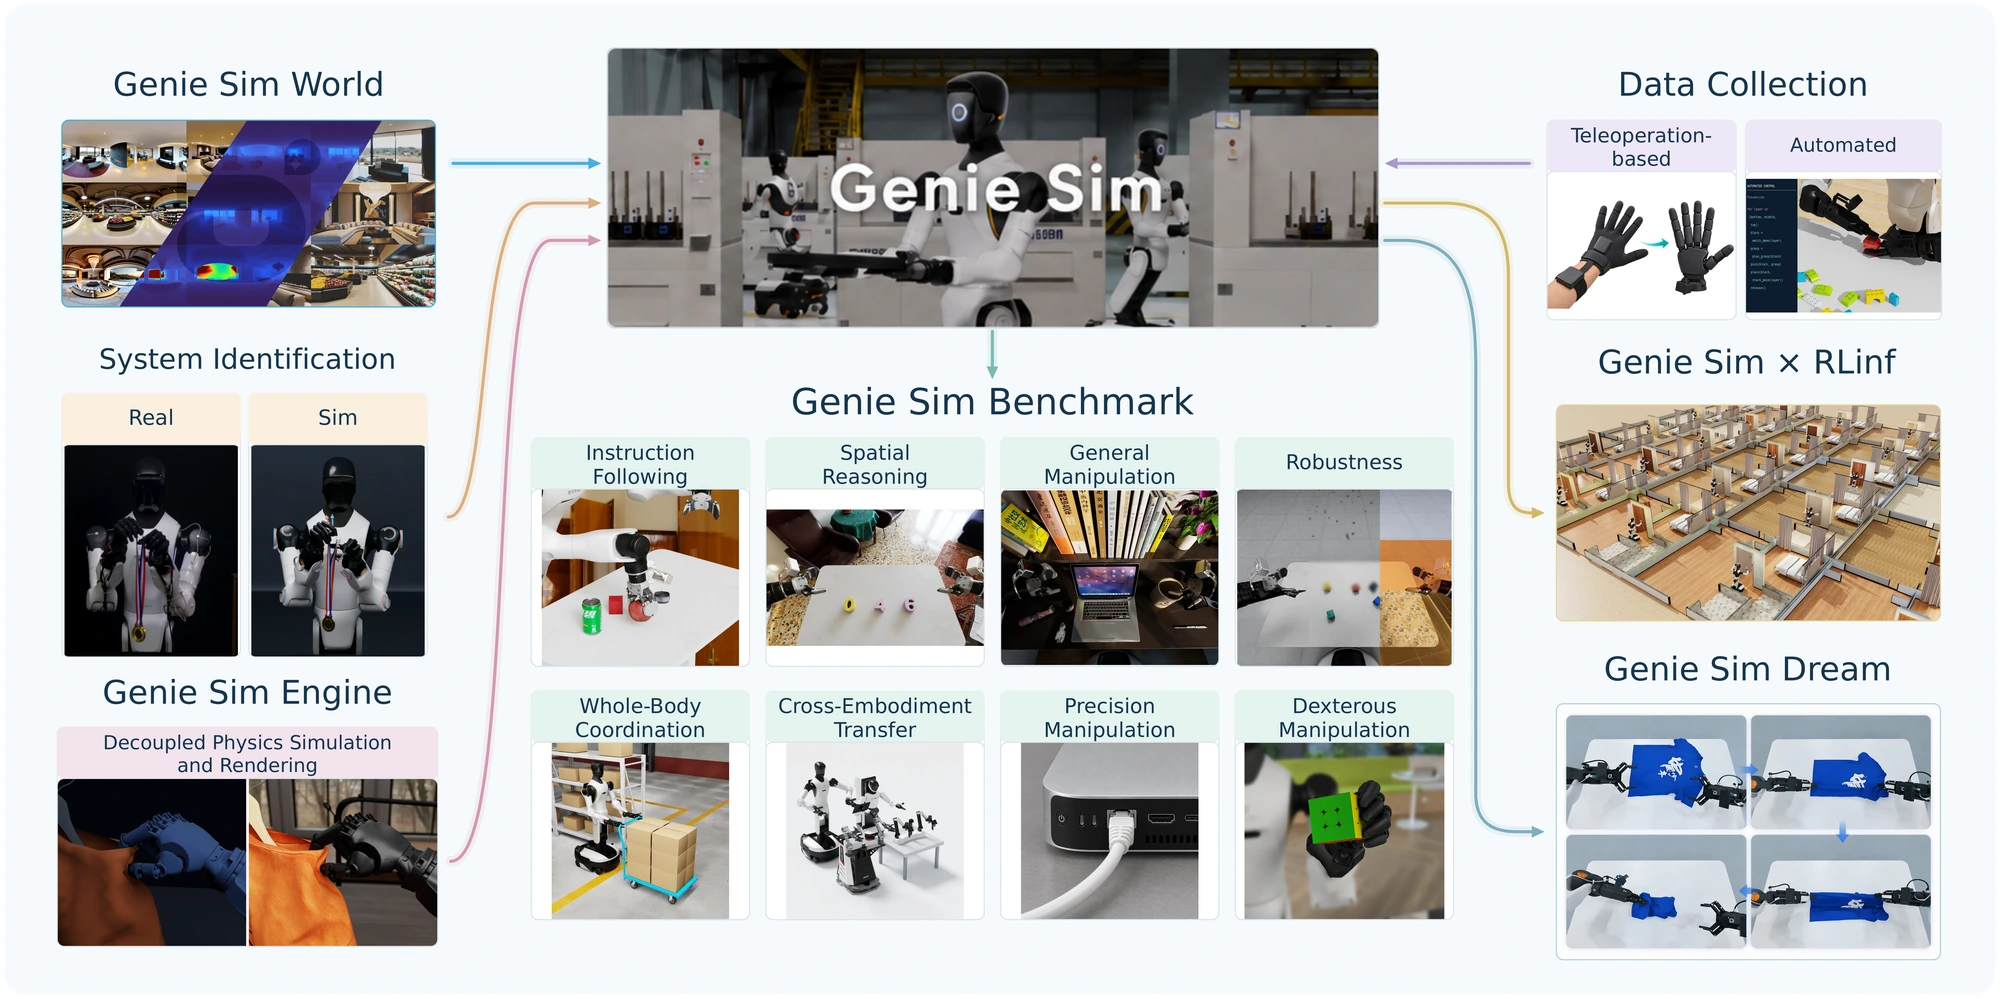
When to Use
- User wants to run an off-tree robot on the RT Engine.
- User has a URDF / xacro that fails to import (missing inertia, unit mismatch, DAE materials lost, OBJ names colliding) and needs the offline mesh-prep tools.
- User wants to add the new robot to a
scene_*.yamland launch it via thelaunch-sceneskill.
Do not use for:
- Tweaking an existing Genie G2 variant → just edit the relevant
URDF / xacro and rebuild via
build-workspace. - Authoring a MoveIt config for the new robot → that's a separate,
larger job (port SRDF +
coupled_constraints.yaml). - Adding a benchmark task that uses the new robot →
run-benchmarkingeniesim_benchmark/skills/.
Critical Patterns
- Tier 1 only validates Genie G2. Reference robots (Franka, UR5, Aloha, ARX, Agilex) have correct URDFs and import cleanly, but scene yamls and physics tuning may be stale. Treat them as starting points, not certified configs.
- AS3 layout is mandatory. The engine expects the per-robot
directory
robot.usda+payloads/Physics/{physics,physx,mujoco}.usdaregardless of which backend is active — switching physics never rewrites the asset. - Fix the URDF before importing.
diagnose_urdf.pycatches missing inertia, zero-mass links, collision/visual mismatches, and bad OBJ name collisions — every one of these breaks the URDF→USD importer downstream. - Mesh names must be unique. USD's flat namespace will silently
merge two meshes that share an OBJ name.
normalize_obj_names.pyrewrites names to be prefix-unique. - Mimic joints handled at runtime. Don't model gripper mimics
inside the URDF — the engine bridges them via the controller
layer (see
86308f040in git history). URDF stays plain. - Robots live in
genie_sim_robot_model, not ingeniesim_assets. Meshes can move togeniesim_assetsonce stabilised, but URDFs + xacros stay in the ROS package.
Workflow
Step 1 — Stage the URDF / xacro
Drop the file under
source/geniesim_ros/src/ros_ws/src/genie_sim_robot_model/urdf/ next
to the reference robots. Name follows the convention
<vendor>_<model>[_<gripper>].urdf.
ls source/geniesim_ros/src/ros_ws/src/genie_sim_robot_model/urdf/
# e.g. franka_fr3.urdf, ur5_robotiq_140.urdf, your_robot.urdf
Step 2 — Diagnose
cd source/geniesim_ros/src/ros_ws/src/genie_sim_robot_model
python scripts/diagnose_urdf.py urdf/<your_robot>.urdf
Look for: missing <inertial>, zero mass, visual/collision link
mismatches, mesh path resolution failures.
Step 3 — Prep meshes
For each issue the diagnose tool flagged:
# OBJ name collisions:
python scripts/normalize_obj_names.py path/to/meshes/

# DAE units off (mm vs m):
python scripts/fix_dae_units.py path/to/meshes/<file>.dae

# DAE materials missing after a re-export:
python scripts/copy_dae_material.py source.dae target.dae

# Missing or wrong inertials (uniform-density approximation):
python scripts/recompute_inertia.py urdf/<your_robot>.urdf
Step 4 — Confirm the URDF imports
Re-run diagnose_urdf.py until it's clean, then build the workspace
(build-workspace skill) and let the engine's URDF→USD importer
stage the AS3 layout on first run. The importer writes:
assets/scenes/<scene>/
├── manifest.json
├── scene.usda
└── robot/
    ├── robot.usda
    └── payloads/
        └── Physics/
            ├── physics.usda
            ├── physx.usda
            └── mujoco.usda
manifest.json presence = cache hit. To force a regenerate:
rm -rf assets/scenes/<scene>/
# or pass:
ros2 launch genie_sim_bringup app.launch.py … always_regenerate_robot_usd:=true
Step 5 — Wire into a scene yaml
Create genie_sim_bringup/config/scene_flat_<your_robot>.yaml
modelled on one of the reference scenes (e.g. scene_flat_fr3.yaml).
Required keys:
robot:
  urdf: <your_robot>.urdf            # filename, resolved against genie_sim_robot_model/urdf/
  init_base_pose:                    # non-physics teleport at spawn
    x: 0.0
    y: 0.0
    z: 0.0
    theta: 0.0
  init_joint_pos:                    # optional, per-joint dict
    joint_name: <value>

viewer_camera:                       # Newton GL viewer default cam
  pos: [1.6, -1.6, 1.2]
  lookat: [0.0, 0.0, 0.8]

scene:
  base_path: <relative_to_geniesim_assets>
  scene_usda: <stage>.usda           # or omit for an empty scene
Step 6 — Launch via launch-scene
ros2 launch genie_sim_bringup app.launch.py \
  scene:=scene_flat_<your_robot> \
  launcher_config:=launcher_ovrtx_isaac_physx \
  headless:=false   # local workstation with a screen; flip to true on a remote/headless host
If anything goes wrong, fall back to the experimental
launcher_newton_mjwarp to see whether the issue is PhysX-specific
or applies to all backends.
Commands (copy-paste summary for the user)
# Inside the container:
cd source/geniesim_ros/src/ros_ws/src/genie_sim_robot_model

# 1. Diagnose
python scripts/diagnose_urdf.py urdf/<your_robot>.urdf

# 2. Mesh prep (only the ones the diagnose tool flagged)
python scripts/normalize_obj_names.py path/to/meshes/
python scripts/fix_dae_units.py path/to/meshes/<file>.dae
python scripts/copy_dae_material.py src.dae dst.dae
python scripts/recompute_inertia.py urdf/<your_robot>.urdf

# 3. Build, then let the engine stage AS3 on first run
cd /workspace
geniesim ros build dev && source devel/setup.bash

# 4. Author scene_flat_<your_robot>.yaml, then:
ros2 launch genie_sim_bringup app.launch.py \
  scene:=scene_flat_<your_robot> \
  launcher_config:=launcher_ovrtx_isaac_physx \
  headless:=false   # local workstation with a screen; flip to true on a remote/headless host
Notes
- The AS3 layout is the same regardless of backend, so a robot that works under Isaac PhysX also works under Newton-standalone — only the physics tuning (gains, contact compliance) may need per-backend trimming.
recompute_inertia.pyassumes uniform density and is only a starting point. For Tier 1 quality, source inertials from the vendor's CAD.- The URDF→USD importer is cache-gated by
manifest.json. Editinginit_joint_posdoes not bust the cache (it's forwarded as a JSON-encoded launch param, not a manifest field) — only changes that affect topology (URDF, xacro args, mimic, fixed-base selection) require a regenerate. - For non-G2 robots, MoveIt is not packaged. The engine runs fine without it; you just don't get planning or RViz interactive markers out of the box.
Resources
- Robot package: source/geniesim_ros/src/ros_ws/src/genie_sim_robot_model/
- Mesh-prep scripts: source/geniesim_ros/src/ros_ws/src/genie_sim_robot_model/scripts/
- Reference URDFs: source/geniesim_ros/src/ros_ws/src/genie_sim_robot_model/urdf/
- Scene yamls: source/geniesim_ros/src/ros_ws/src/genie_sim_bringup/config/
- Engine overview: source/geniesim_ros/README.md
- Package routing: source/geniesim_ros/AGENTS.md