
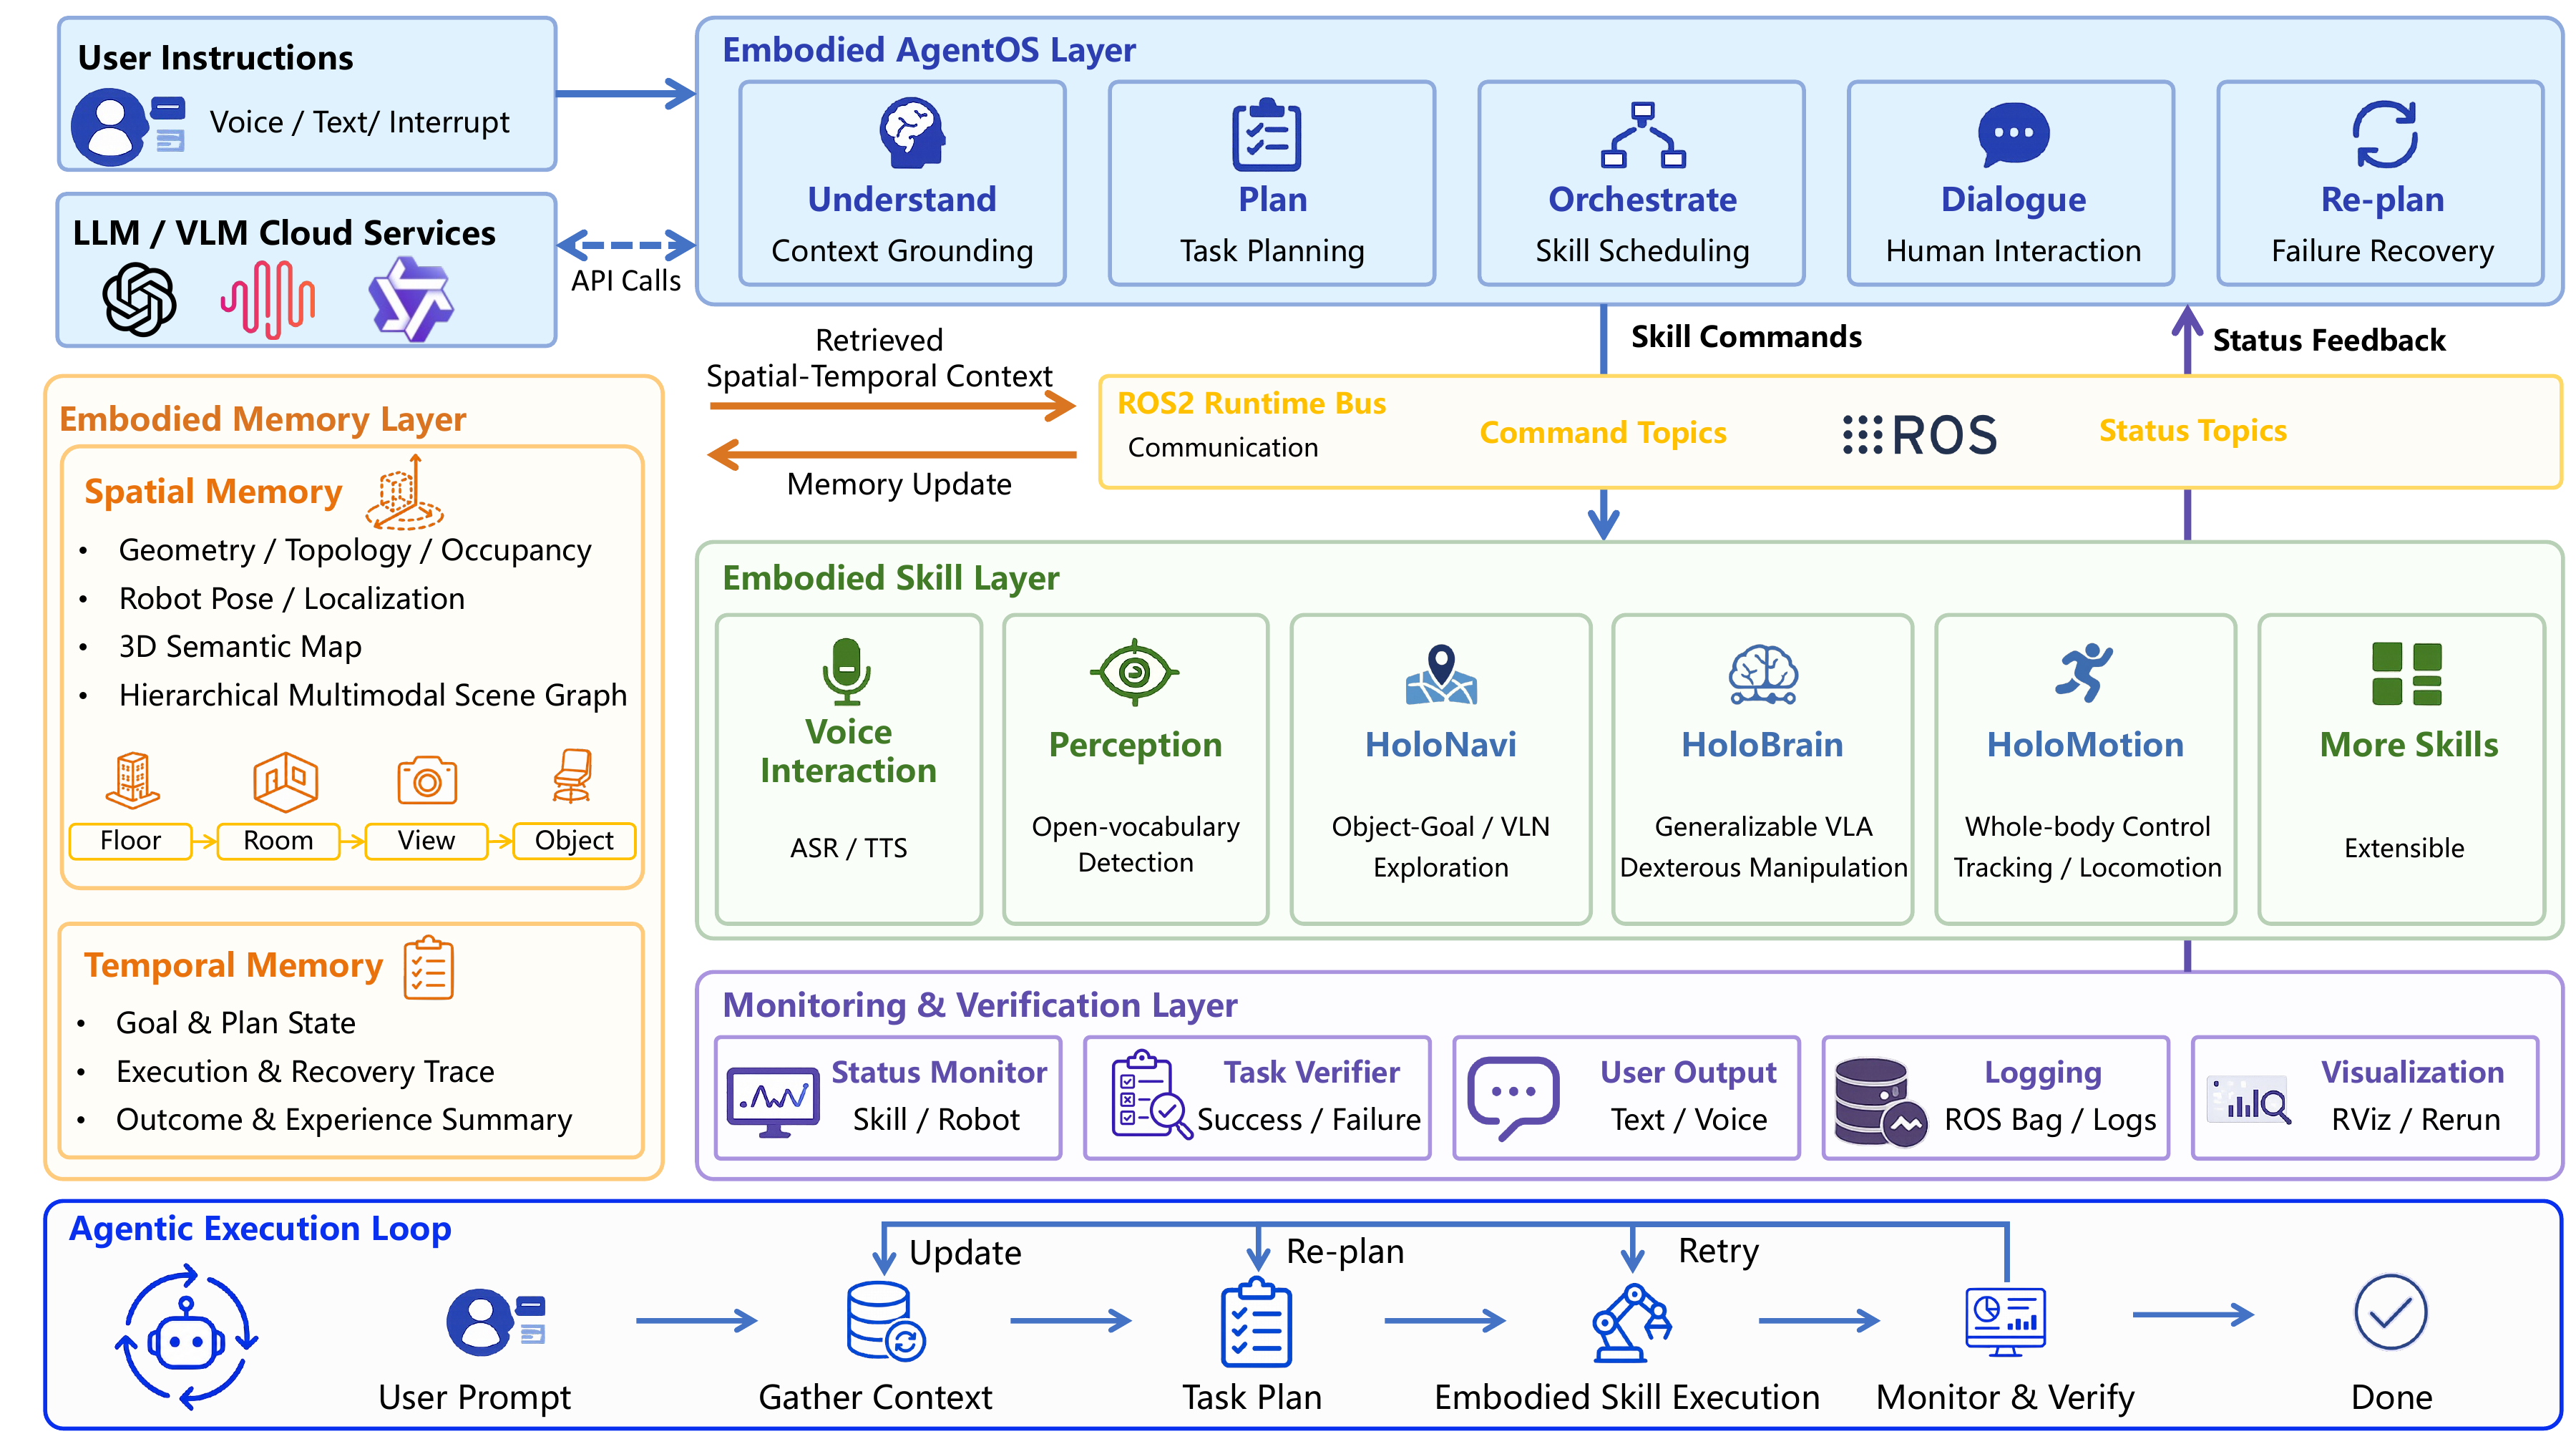
Robot Service
This skill documents the canonical external control surface for OpenClaw robots.
Architecture
Layer 1: robot_bridge on each robot
Default robot-side HTTP server:
- host:
0.0.0.0 - port:
8000
Supported mappings:
Navigation signal
POST /api/navigation/{name}- ROS topic:
chat_signal_pub
Relative navigation
POST /api/relative_nav- ROS topic:
/relative_nav - JSON body:
{"cmd": "forward,left,degrees"}
Semantic navigation
POST /api/semantic_nav- ROS topic:
/chat_loc_pub - JSON body:
{"cmd": "floor,room,object"}
Arm skill
POST /api/arm/{skill}- ROS topic:
arm_signal_pub
Stop navigation
POST /api/navigation/stop- ROS topic:
chat_signal_pub
Health check:
GET /health
Layer 2: multi_robot_ctl on the master machine
Default control-center port:
8080
Supported fan-out endpoints:
POST /trigger/one_point_1POST /trigger/one_point_2POST /trigger/one_point_3POST /trigger/one_point_4POST /trigger/multi_point_1POST /trigger/multi_point_2POST /trigger/stop
Optional query parameter:
robot_id=<id>robot_id=all
Workflow
- Identify whether the request should go to a single robot bridge or the multi-robot control layer.
- Confirm the target endpoint, robot scope, and payload format before sending the request.
- Prefer documented HTTP endpoints and only fall back to ROS topics when appropriate for the integration.
- Execute one service request at a time and inspect the returned status.
- Report the endpoint, payload, and result clearly for downstream workflow tracking.
Safety Rules
- If the target robot is ambiguous, ask which robot should execute.
- If the command is unsafe or unclear, do not trigger the service.
- If unsure, stop and clarify.
Examples
See:
README.mdassets/service_examples.sh